Concept demonstration
Autonomous Robot Simulator
Visualize autonomous robotic systems navigating complex environments.
This page describes a design study SATHURIX can discuss with a client. It is not a completed customer deployment.
Project overview
Problem
A route and its blocked-aisle cases need a test before a physical trolley moves.
Proposed solution
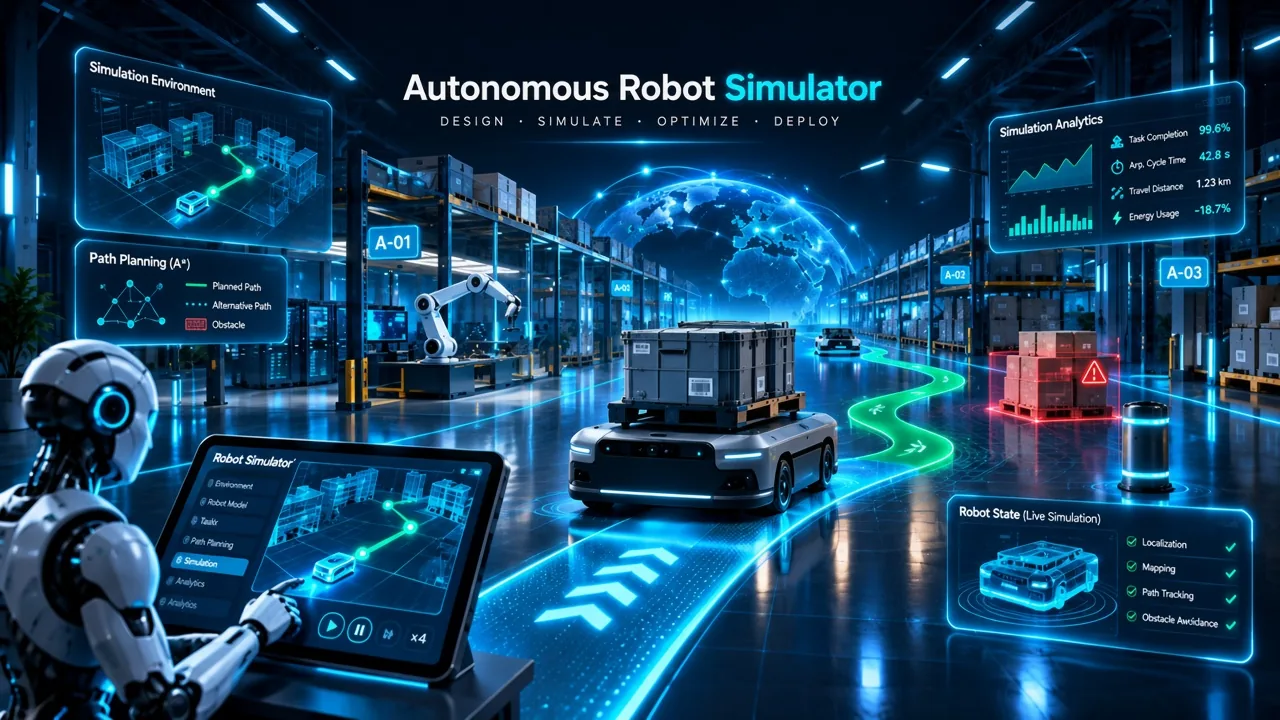
An autonomous warehouse trolley is planned and tested in simulation before it moves on a real floor. A map of the aisles, a path planner and obstacle avoidance run as ROS 2 nodes, and the simulator shows the planned path, the alternative it takes when an obstacle appears, and the robot state at each step.
How the study is framed
- 1.Build the simulated map from real aisle measurements, not an idealised layout.
- 2.Run the same ROS 2 navigation stack in simulation and on the robot.
- 3.Keep a hardware emergency stop that does not depend on the navigation software.
Demonstration
This study has no screen recording. The interactive simulation is the demonstration.
Open interactive simulationWhere this could help
Potential benefit: routes and edge cases are tested in software before a physical robot is put at risk.
Discuss this project
Tell us which part of this design study matches the site you operate. The conversation is about a possible build, not a system already running.
Discuss this project