Concept demonstration
ROS 2 Autonomous Trolley
A design study for an indoor trolley that follows a mapped route, tried in Gazebo before a physical platform moves.
This page describes a design study SATHURIX can discuss with a client. It is not a completed customer deployment.
Project overview
Problem
An indoor route should be rehearsed, including a stop, before a physical platform is booked.
Proposed solution
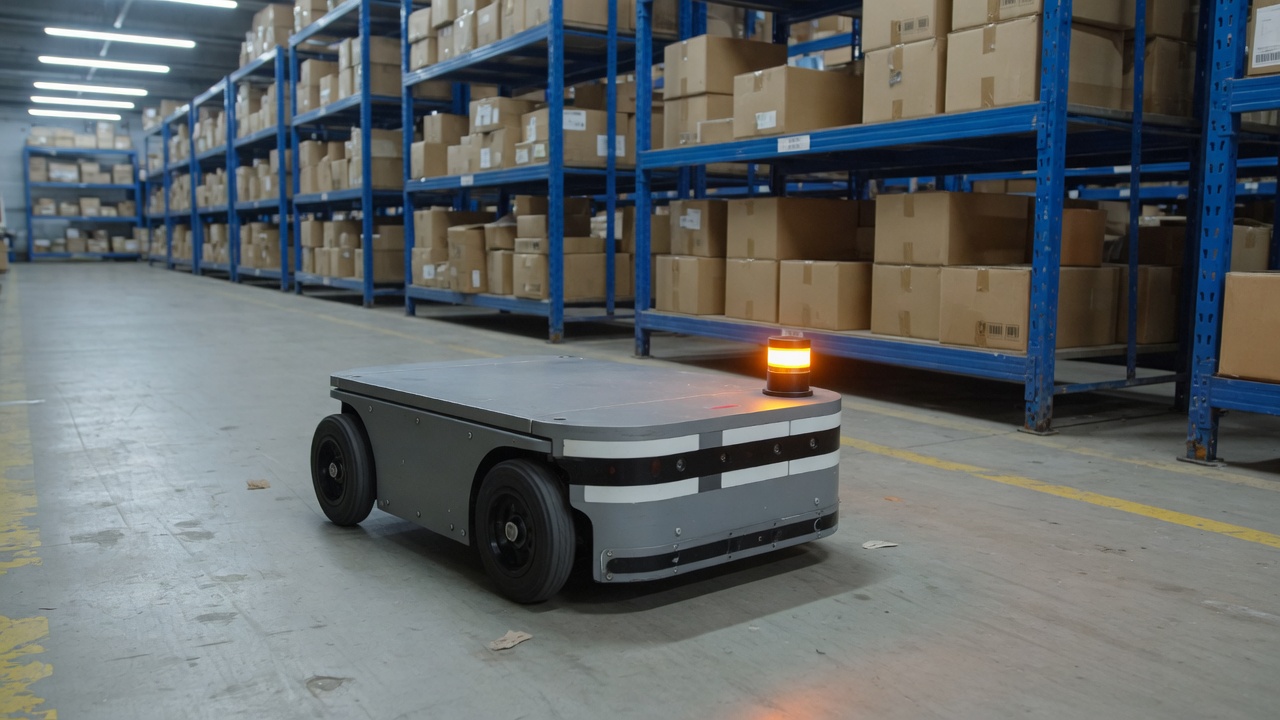
The study uses ROS 2 for localisation and path following, a Raspberry Pi-class computer on the platform, and Gazebo to rehearse the route. The trolley stops when the localisation is poor or the path is blocked. It is a concept for a controlled indoor space, not a record of an autonomous vehicle in service.
How the study is framed
- 1.Build the map from a site walk and mark the areas the trolley is not allowed to enter.
- 2.Simulate the route, including a blocked aisle, before booking hardware time.
- 3.Keep a manual stop on the platform that does not depend on the navigation software.
Demonstration
The recording below is the existing demonstration. It stays on this page with the interactive simulation.
Discuss this project
Tell us which part of this design study matches the site you operate. The conversation is about a possible build, not a system already running.
Discuss this project